
Tohoku Univ. Technology:FPGA-Based Highly Parallel Architecture:T25-012
Enabling real-time autonomous control for mobile agents in dynamic environments
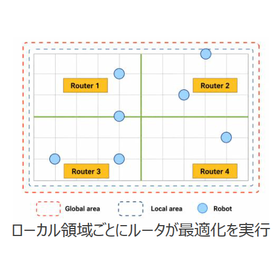
Japan faces a severe driver shortage, with 36% of logistics demand potentially stagnating by 2030. While AGVs are a key solution, conventional path planning faces computational bottlenecks and high costs for proximity sensors. This technology implements a proprietary NoC-inspired architecture on FPGA, replacing "global batch computation" with "highly parallel local region processing." By dividing the domain into areas managed by router kernels, the system emulates agent movements significantly faster than real-time. This allows pre-emptive collision and deadlock detection, enabling safe, low-cost, real-time autonomous control in large-scale environments with minimal sensor dependency.
- Company:Tohoku Techno Arch Co., Ltd.
- Price:Other
